Store

 EN
 CN
 VI
 IT
 ES
 TH
 JA
 PT
 MS
 KO
 FR
 DE
 ID


Engineering Motion
Beyond Limits.
Combining axial flux motors, miniature cycloidal reducers and ultra-micro drive technologies, we power the next generation of robots, precision devices and intelligent machines.

Driving Performance
at the Smallest Scale.
at the Smallest Scale.
Ultra-micro brushless & coreless motors engineered to deliver fast response, high efficiency and reliable motion across demanding space-constrained applications.
Why VAXOR
- 01
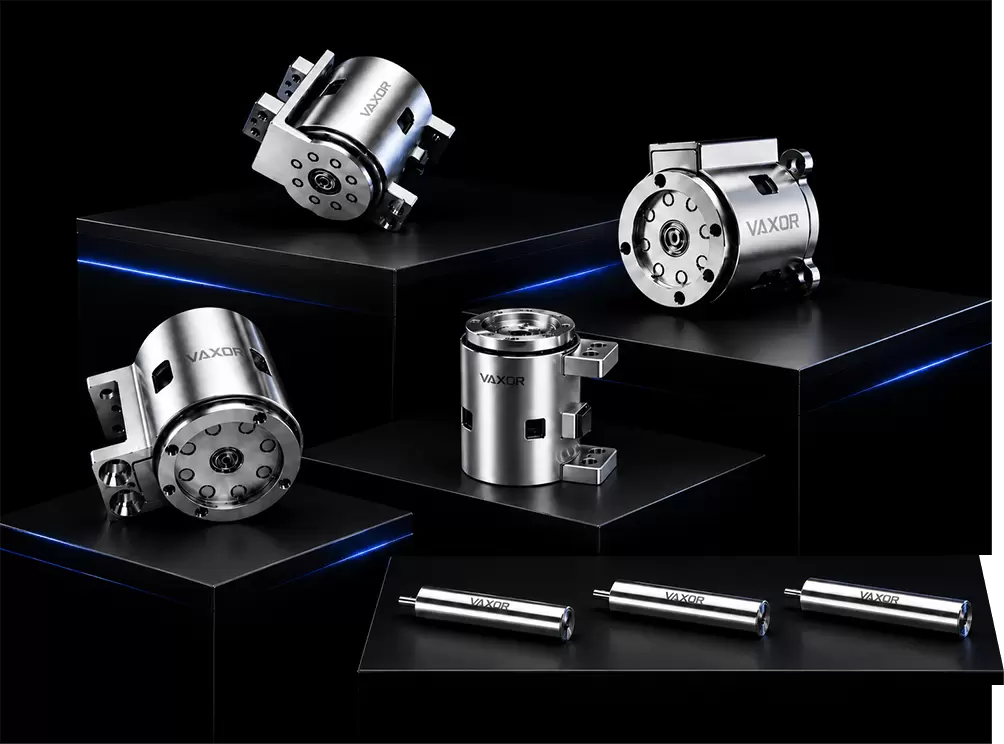
Pioneering Axial Flux Motors at the Micro Scale
Breaking the limits of conventional radial motors with a proprietary PCB axial flux architecture delivering higher power density and torque in a thinner footprint.
- 02
From Motor to Motion System
Combining motors, reducers, sensors and drive electronics into a highly integrated motion platform.
- 03
Engineered for Next- Generation Robotics
Designed for dexterous hands, humanoid robots and advanced intelligent devices requiring compact, high-performance motion systems.
PRODUCTS


A REVOLUTION IN PERFORMANCE
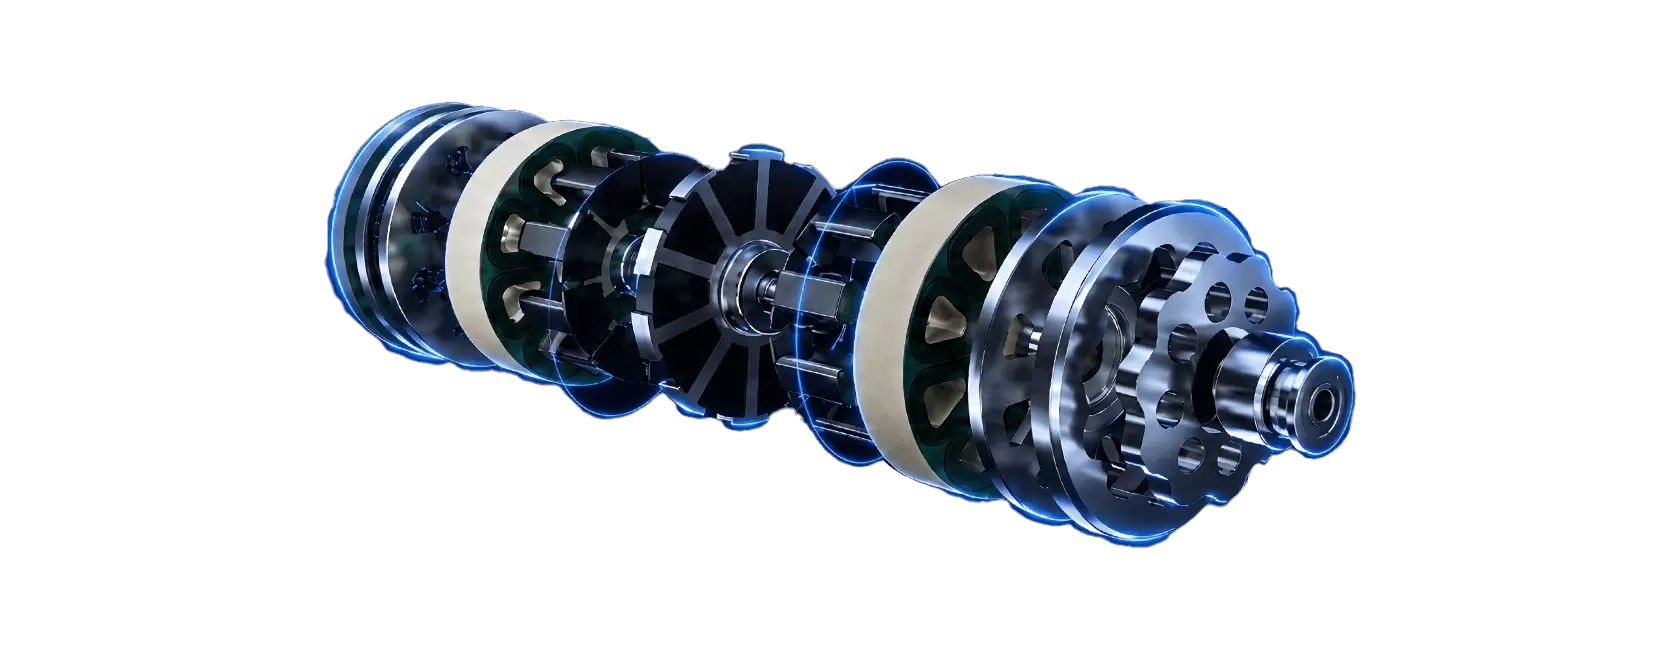
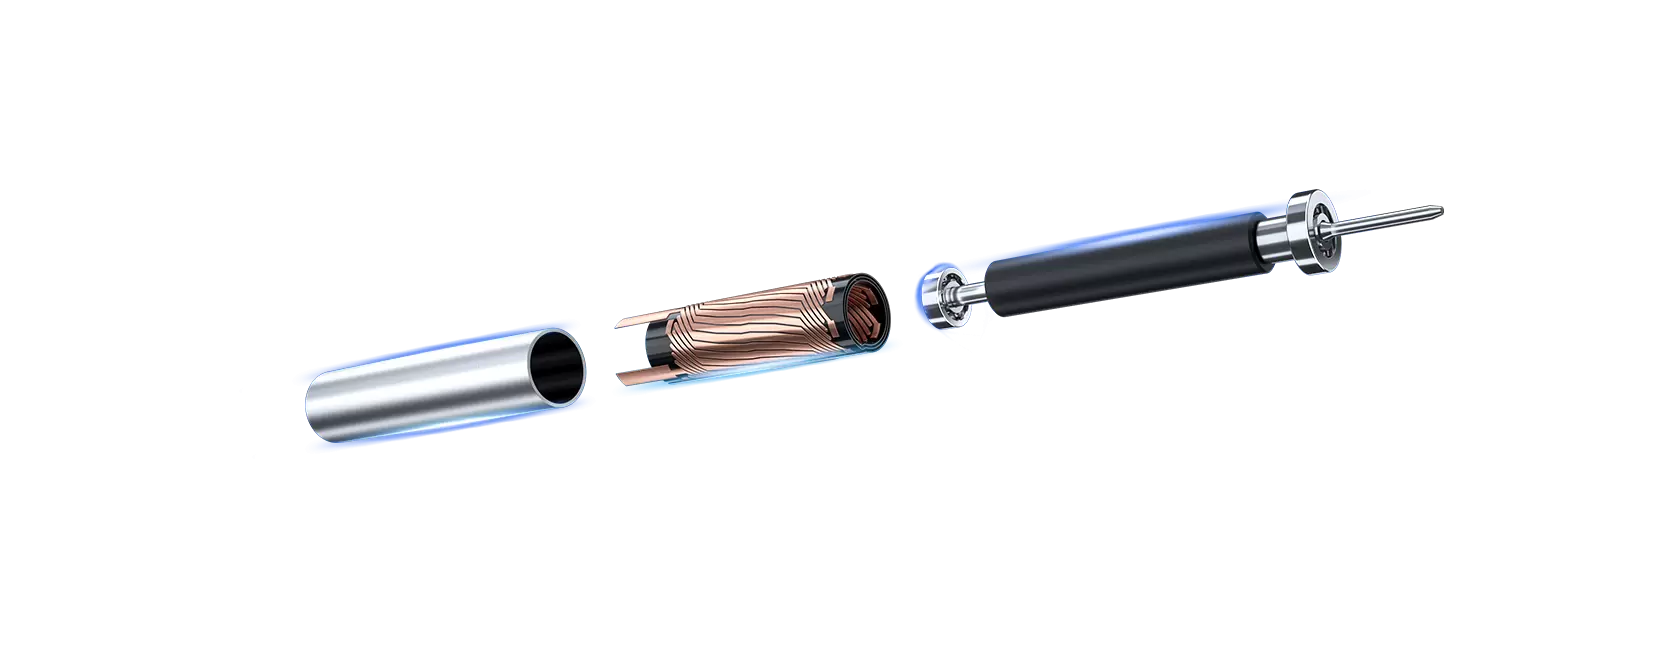
Advanced Electromagnetic Design
Faster response. Better efficiency.
Miniature Cycloidal Gear
Precision motion with exceptional control.
Axial Flux Motor
Higher torque density in a compact footprint.
APPLICATION
01/ 07
From dexterous manipulation to autonomous mobility, VAXOR technologies power the next generation of intelligent machines.


BRAND STRENGTH
Driven by innovation. Built on expertise. Trusted by partners worldwide.
 100+Core Founding Team
 1,000,000+Annual Production Capacity
 90%Product Yield
 17+Patent Portfolio
 100+Partners
NEWS ROOM
- 01
Selecting a 4mm Coreless Motor for Compact Medical Devices
Oct.14.202610.14.2026Selecting a 4mm Coreless Motor for Compact Medical Devices
Designing compact medical devices often involves a difficult trade-off between available space and required mechanical performance.
View Detail
- 02
Sizing a Φ30mm Micro Joint Actuator for Humanoid Robot Elbow Loads
Oct.13.202610.13.2026Sizing a Φ30mm Micro Joint Actuator for Humanoid Robot Elbow Loads
The elbow joint of a humanoid robot must do more than lift an object.
View Detail
- 03
Matching Micro Joint Actuator Torque to Collaborative Robot Loads
Oct.12.202610.12.2026Matching Micro Joint Actuator Torque to Collaborative Robot Loads
Collaborative robots need to perform accurate, repeatable movements while operating within tight space and weight limits.
View Detail
- 04
15:1, 30:1 or 50:1? Selecting the Right Micro Actuator Gear Ratio
Oct.10.202610.10.202615:1, 30:1 or 50:1? Selecting the Right Micro Actuator Gear Ratio
Choosing a gear ratio for a robotic joint is not simply a matter of maximizing output torque.
View Detail